Sensitivity, uncertainty and calibration
Which parameters matter, how much a result spreads when they are uncertain, which values
make the model match a measurement, and which value hits a design target: the
workbench's Analysis mode and four diokle commands answer these on any model,
with no scripting.
| Question | Command | Analysis tab |
|---|---|---|
| Which parameters drive this output, and when? | sensitivity |
Sensitivity |
| How much does the result spread? Which inputs cause the spread? | montecarlo, gsa |
Uncertainty |
| Which parameter values fit my measurements? | calibrate |
Calibrate |
| Which value meets my target? | optimize |
Optimize |
| How does a scalar depend on many parameters? | sensitivity --adjoint |
Sensitivity (adjoint) |
| Which factors and interactions matter, over a designed set of runs? | doe |
DOE |
Only free parameters can be varied: public parameters with a literal value, the ones that are editable in the variable browser. Parameters computed from others, protected ones and those evaluated at translation give an error that lists the free ones.
In the workbench
Simulate a model, switch to Analysis in the toolbar and tick the parameters to vary. Each tab has its own settings and Run; a progress bar shows while it runs and Cancel stops it.
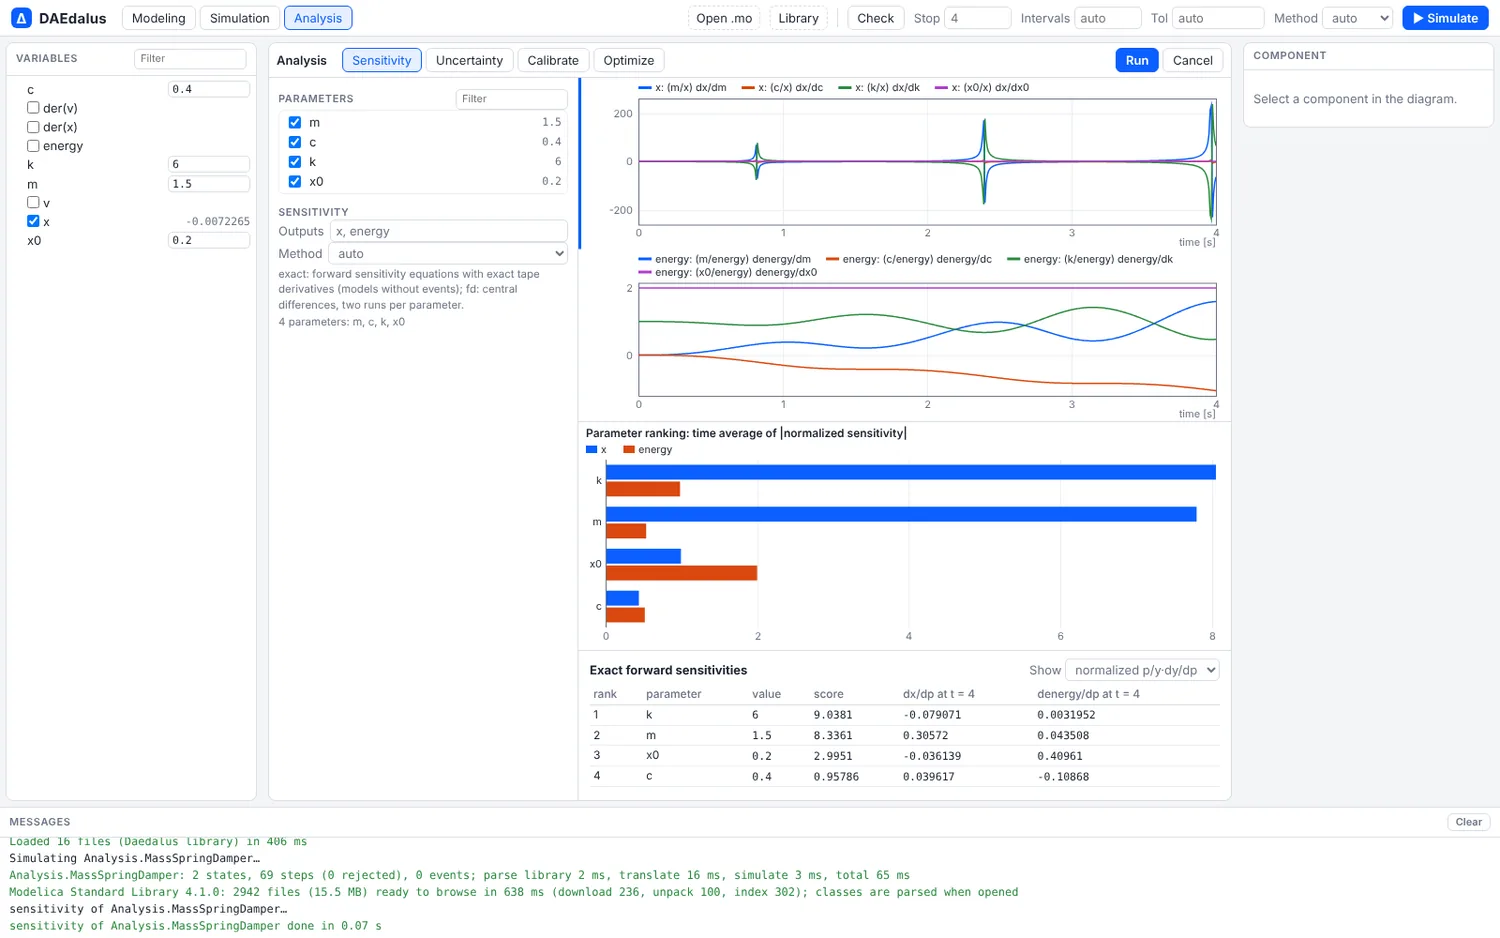
dy/dp over time for each parameter, and a ranking by the time average of the normalized sensitivity.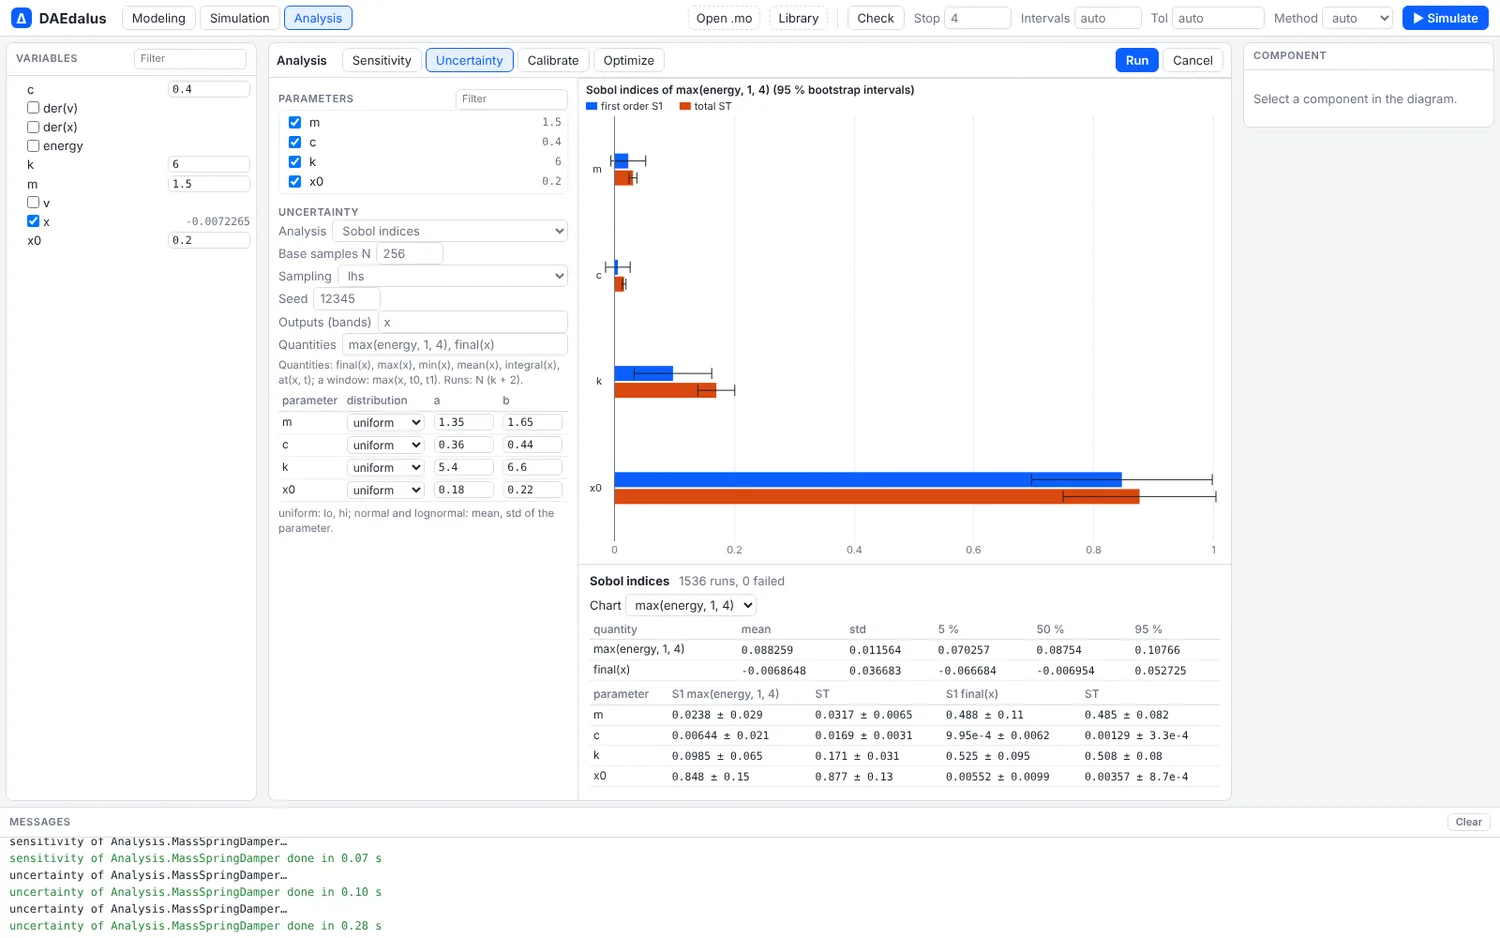
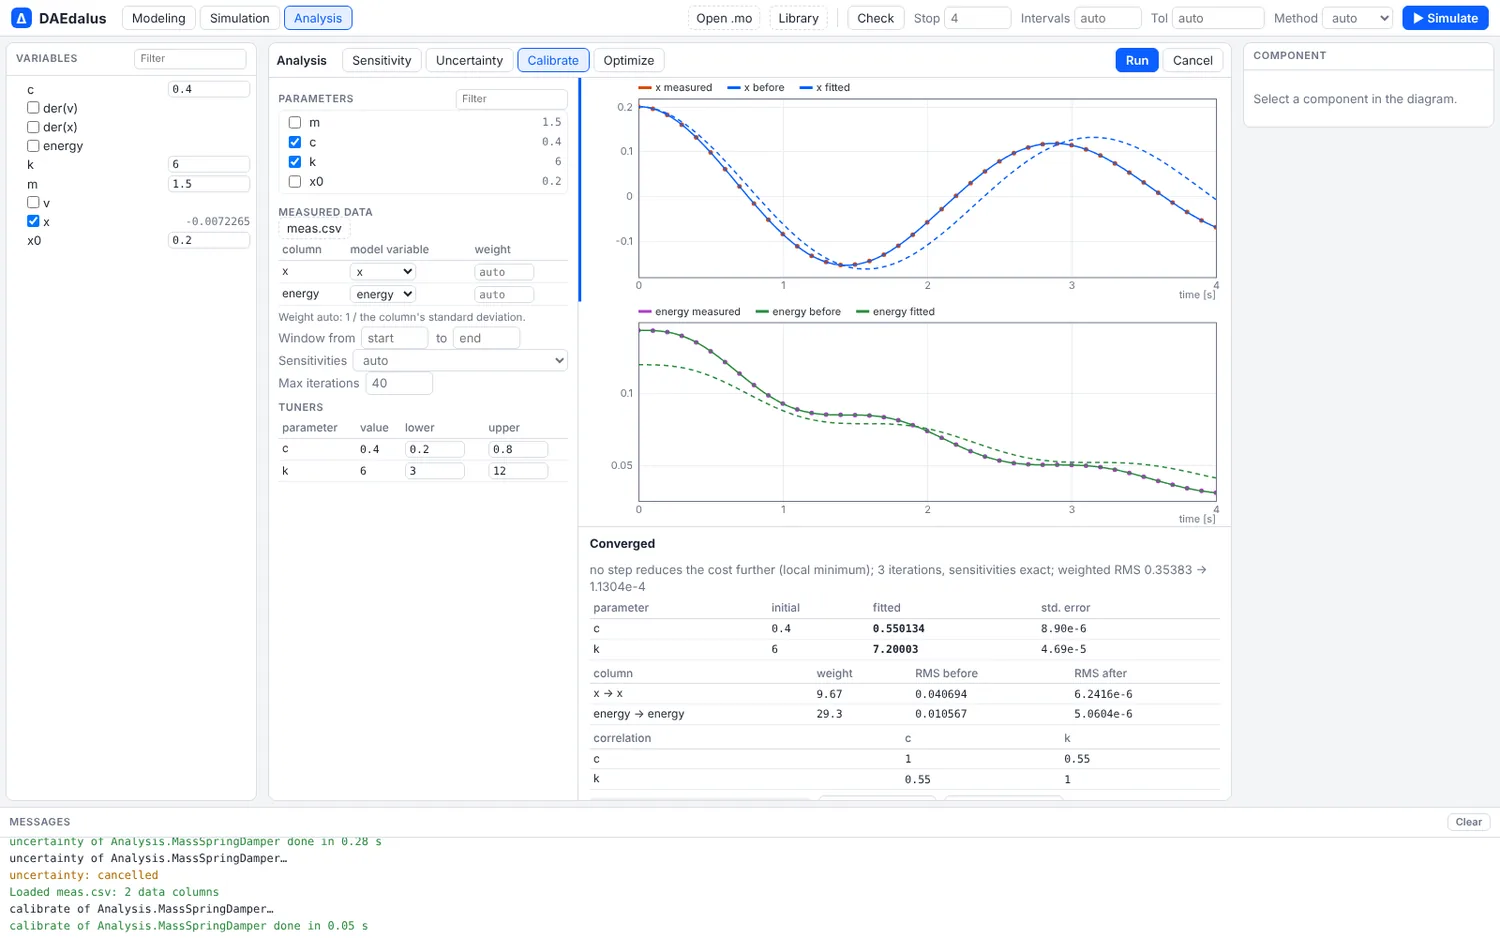
The Calibrate tab loads a CSV, maps its columns to model variables and sets the bounds of each tuner. It plots the measured data against the model before and after the fit, lists the fitted values with standard errors and correlations, and Copy as modifier gives the result as a Modelica modification.
The math in brief
Write the model as , , with parameters .
Sensitivities are the partial derivatives : how much an output moves when a parameter moves. The exact way is the forward sensitivity equation, which Diokle solves together with the model,
When the exact method fails, a central difference is used instead, .
Adjoint gradients are for one scalar and many parameters. One backward solve of the adjoint equations gives every at once,
The formula above is for parameters that enter the model equations; a parameter in the initial state adds one more term, . Its cost does not grow with the number of parameters, so it suits a model with hundreds of them.
Calibration minimizes the weighted squared error between measurements and the model,
by Levenberg–Marquardt steps , where holds the
residuals and the sensitivities of the outputs. The --tune name=lo:hi bounds are the
projection that keeps every step inside the box.
Design of experiments runs the model at chosen factor settings, then fits a quadratic
response surface. With factors coded to (x = (p - center) / half-range),
and the reported tells how much of the variation of each quantity the surface explains. Three factors give 10 terms, as in the example below.
Sensitivity
diokle sensitivity library/Diokle -m Diokle.Examples.QuarterCar.BumpComparison \
    --params linear.m_body,linear.c_spring,linear.c_tyre,bump.h --outputs linear.a_body
sensitivities of Diokle.Examples.QuarterCar.BumpComparison (central finite differences), 2001 points from t = 0 to 2
note: finite differences used because the exact method failed: step size too small at t = 0.008507344142682349
note: central differences, relative step 1e-4, tolerance 1e-8
ranking (time average of |p/y dy/dp|, summed over outputs):
1. linear.m_body 2.60659e0 (p = 400)
2. linear.c_spring 1.74835e0 (p = 30000)
3. bump.h 1.20881e0 (p = 0.05)
4. linear.c_tyre 5.00852e-1 (p = 250000)--sens-method chooses how:
exactintegrates the forward sensitivity equationsds/dt = df/dx s + df/dpnext to the state, with exact tangents of the compiled model, algebraic loops included. It needs a model withoutwhenclauses anddelay(), and a run without events.fduses two runs per parameter with a relative step of 1e-4 at a tightened tolerance.auto(the default) usesexactwhere it applies and otherwise says why it usedfd, as above, where the hydraulic damper's fast start stops the exact method.
The output holds the time series of dy/dp and of the normalized p/y dy/dp, and -o
writes them as JSON or CSV.
Adjoint gradients
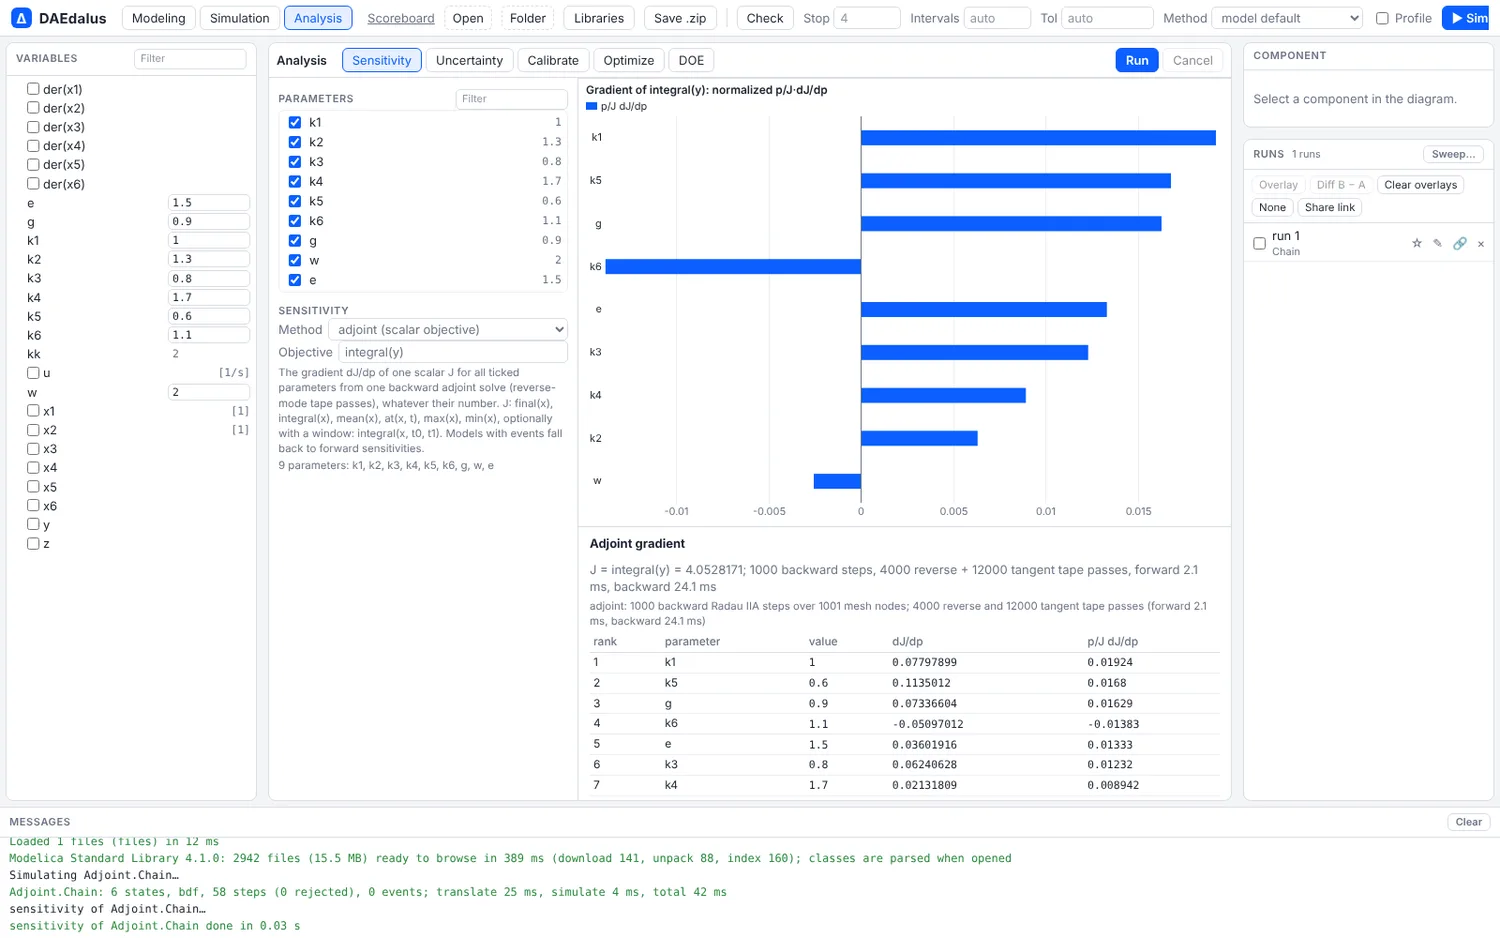
With many parameters and one scalar to differentiate, --adjoint computes the whole
gradient for about the cost of one forward and one backward solve, however many
parameters there are:
diokle sensitivity crates/diokle-core/tests/models/adjoint.mo -m Adjoint.Chain --adjoint \
    --objective 'integral(y)' --params k1,k2,k3,k4,k5,k6,g,w,e
gradient of integral(y) for Adjoint.Chain (adjoint: backward solve with reverse-mode tape passes)
note: adjoint: 1000 backward Radau IIA steps over 1001 mesh nodes; 4000 reverse and 12000 tangent tape passes (forward 0.8 ms, backward 10.1 ms)
J = 4.0528170837e0
parameter value dJ/dp p/J dJ/dp
k1 1.000000e0 7.79789943e-2 1.9241e-2
k5 6.000000e-1 1.13501154e-1 1.6803e-2
g 9.000000e-1 7.33660425e-2 1.6292e-2
k6 1.100000e0 -5.09701197e-2 -1.3834e-2
e 1.500000e0 3.60191614e-2 1.3331e-2
k3 8.000000e-1 6.24062793e-2 1.2319e-2
k4 1.700000e0 2.13180931e-2 8.9421e-3
k2 1.300000e0 1.97269796e-2 6.3277e-3
w 2.000000e0 -5.16754637e-3 -2.5501e-3Nine parameters, one backward solve of about 10 ms.
- Objectives:
final(x),at(x,T),integral(x)ormean(x), with an optional window such asintegral(x,T0,T1).maxandminare differentiated at the maximum or minimum on the output grid. - The backward pass solves
-dλ/dt = (df/dx)ᵀ λ + (dg/dx)ᵀwith a two-stage Radau IIA step, and eachf_pᵀ λis one reverse pass over the compiled model, algebraic loops included. --grad-method auto|adjoint|forward|fd:autouses the adjoint and falls back to forward sensitivities or differences for models with events, saying why.- The gradients agree with forward sensitivities and central differences to about 1e-7
relative on the test models (
crates/diokle-core/tests/adjoint.rs).
The same gradients drive optimize --algorithm lbfgsb and calibrate --optimizer lbfgsb
(bound-constrained L-BFGS-B). On a 6-state chain with 9 parameters, L-BFGS-B converges in
about 5 runs plus 5 gradients, where Nelder–Mead needs several hundred runs.
Uncertainty and global sensitivity
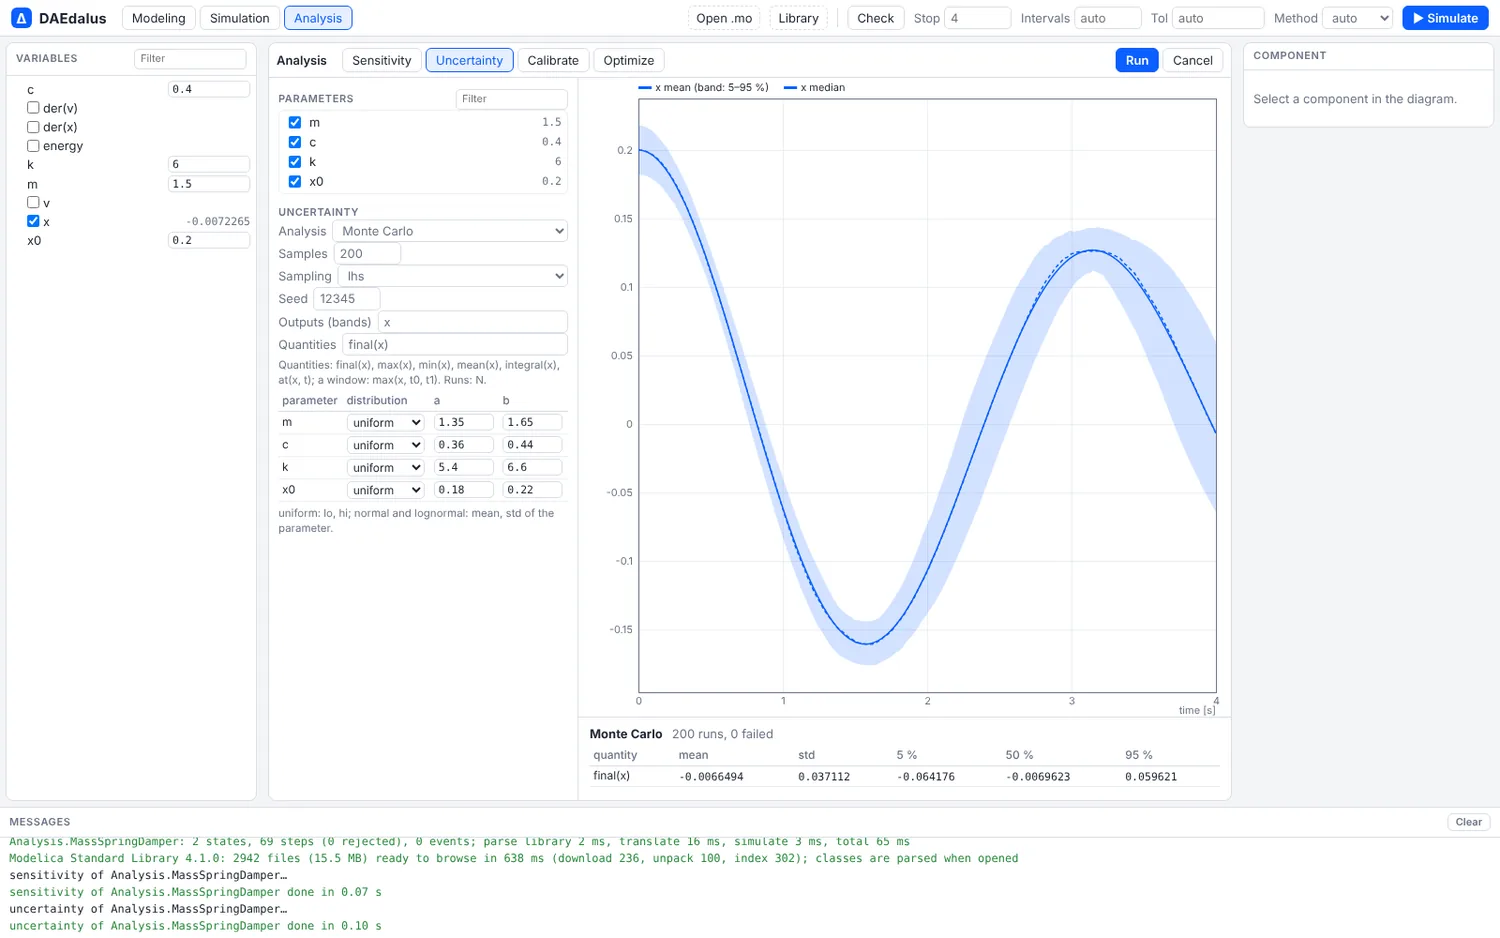
montecarlo samples the parameters from their distributions and reports the mean,
standard deviation and the 5, 50 and 95 % bands of each output; gsa adds Sobol indices
(first-order and total, in N (k + 2) runs) or Morris screening (--morris). Runs use all
cores.
diokle gsa library/Diokle -m Diokle.Examples.QuarterCar.BumpComparison \
    --dist linear.m_body=250:350 --dist linear.c_spring=20e3:40e3 --dist bump.h=normal:0.05:0.01 \
    --qoi 'max(linear.a_body)' -N 128
Sobol indices of Diokle.Examples.QuarterCar.BumpComparison: 640 runs, 0 failed
quantity mean std 5% 50% 95%
max(linear.a_body) 1.64112e1 3.72167e0 1.04179e1 1.62511e1 2.29829e1
max(linear.a_body) (mean 1.64266e1, variance 1.45367e1):
parameter S1 ST
linear.m_body 0.1981 +-0.088 0.1619 +-0.046
linear.c_spring 0.0079 +-0.028 0.0111 +-0.003
bump.h 0.6979 +-0.191 0.6082 +-0.129The bump height explains about 70 % of the spread in peak body acceleration and the spring rate almost none. That took 14.5 s for 640 runs on four cores.
- Distributions:
p=lo:hi(uniform),p=normal:MEAN:STD,p=lognormal:MEAN:STD; Latin hypercube or random sampling (--sampling), seeded (--seed). - Quantities:
final(x),max(x),min(x),mean(x),integral(x)andat(x,T), each with an optional window such asmax(x,T0,T1).
Calibration
calibrate fits parameters to measured data with a projected Levenberg–Marquardt method.
The CSV has a time column and measured columns, matched to variables by name or with
--map column=var. Here the measurement is a simulated run with m_body = 360 and
c_spring = 36000, with Gaussian noise added, and the fit starts from the model's 400 and
30000. Make the file with a seeded noise step:
diokle simulate library/Diokle -m Diokle.Examples.QuarterCar.BumpComparison \
    -p linear.m_body=360 -p linear.c_spring=36000 --vars linear.a_body,linear.body.s -o meas0.csv
python3 - <<'EOF'
import csv, random
random.seed(1)
rows = list(csv.reader(open('meas0.csv')))
out = [rows[0]] + [[r[0]] + [str(float(x) + random.gauss(0, 0.02 * abs(float(x)) + 1e-3))
                             for x in r[1:]] for r in rows[1:]]
csv.writer(open('meas.csv', 'w', newline='')).writerows(out)
EOF
The fitted values depend on the seed:
diokle calibrate library/Diokle -m Diokle.Examples.QuarterCar.BumpComparison \
    --data meas.csv --tune linear.m_body=250:500 --tune linear.c_spring=15e3:50e3
calibration of Diokle.Examples.QuarterCar.BumpComparison: 4 iterations, 4052 residuals, sensitivities: finite differences
converged: cost and step no longer decrease
weighted residual RMS: 6.810141e-1 -> 6.676438e-1
parameter initial fitted std. error
linear.m_body 4.0000000e2 3.6174678e2 3.761e0
linear.c_spring 3.0000000e4 3.5693377e4 9.340e2
correlation:
[ 1.000 0.342]
[ 0.342 1.000]
column weight RMS before RMS after
linear.a_body 5.1789e-1 3.021453e-1 4.033338e-2
linear.body.s 7.2494e1 1.310878e-2 1.302128e-2
modifier: (linear(m_body = 361.74678, c_spring = 35693.377))Weights default to one over each column's standard deviation (--weight changes them),
and --window T0:T1 restricts the fit in time.
Optimization
optimize runs Nelder–Mead inside the bounds. The objective is the sum of
--minimize q, --maximize q and --target q=v terms, with the same quantities as
above. Which body mass brings the peak body acceleration over the bump down to 10 m/s²?
diokle optimize library/Diokle -m Diokle.Examples.QuarterCar.BumpComparison \
    --tune linear.m_body=250:600 --target 'max(linear.a_body)=10'
optimization of Diokle.Examples.QuarterCar.BumpComparison (Nelder-Mead): 29 iterations, 58 runs; simplex converged
objective: 5.751403e0 -> 2.923810e-17
max(linear.a_body): 1.239821e1 -> 1.000000e1
parameter initial optimal
linear.m_body 4.0000000e2 5.0070870e2
modifier: (linear(m_body = 500.7087))Dynamic optimization, where the inputs vary over time and constraints apply along the trajectory, is the job of the CasADi export.
Design of experiments
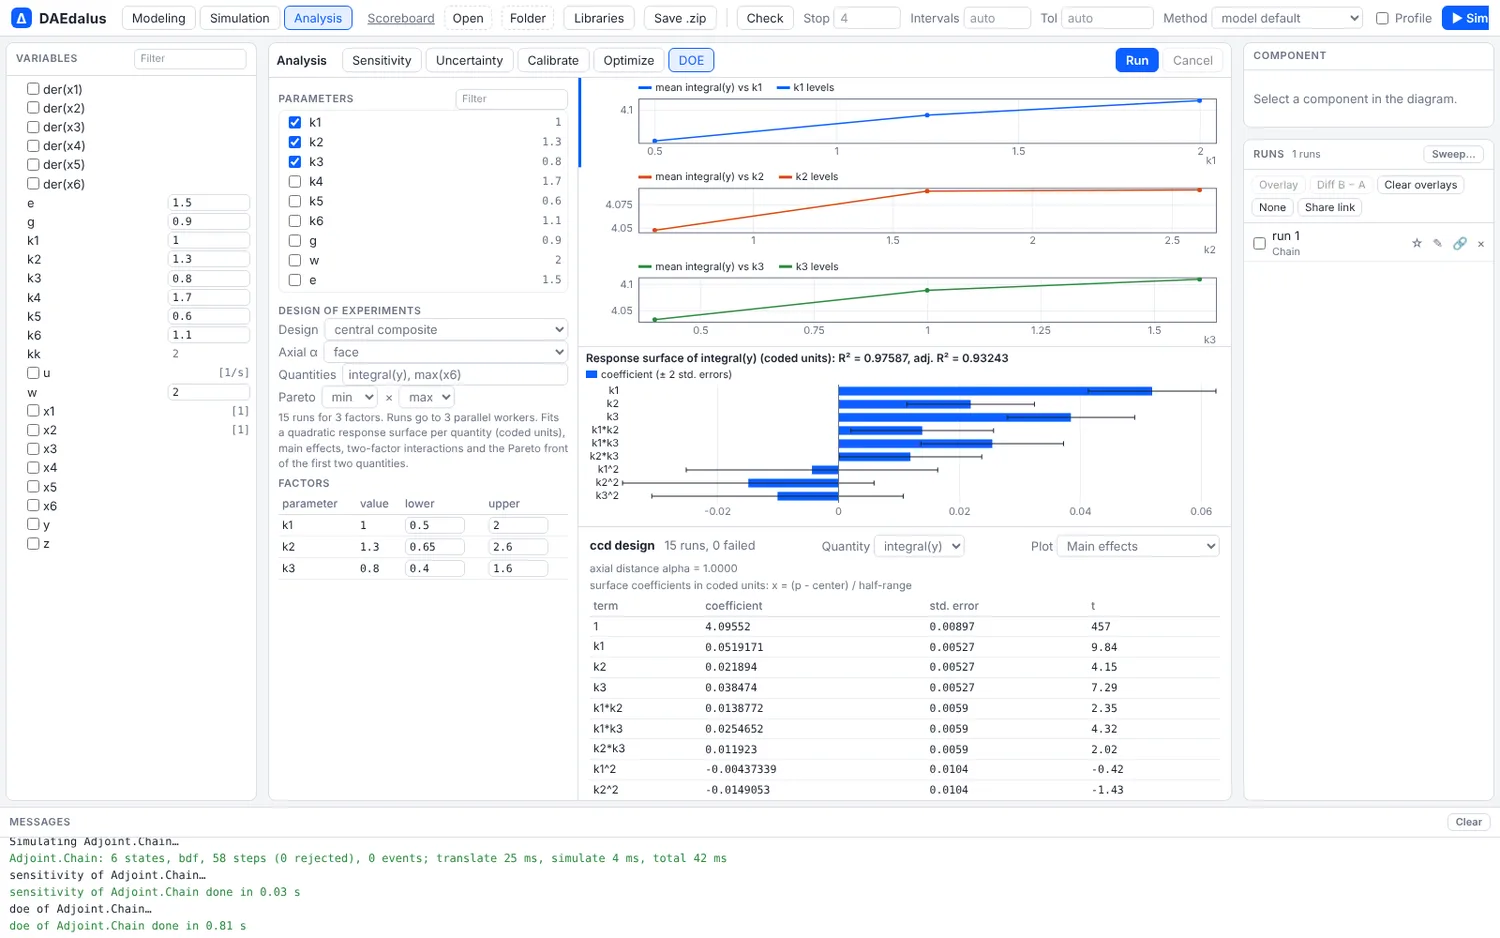
diokle doe runs a designed set of experiments and fits a quadratic response surface
to each quantity. Three factors on the quarter car, in a central composite design:
diokle doe library/Diokle -m Diokle.Examples.QuarterCar.BumpComparison \
    --factor linear.m_body=300:500 --factor linear.c_spring=20e3:40e3 --factor bump.h=0.03:0.07 \
    --design ccd --qoi 'max(linear.a_body)' --qoi 'max(linear.body.s)' --pareto min,min
central composite design of Diokle.Examples.QuarterCar.BumpComparison: 15 runs over linear.m_body, linear.c_spring, bump.h, 0 failed
note: surface coefficients in coded units: x = (p - center) / half-range
max(linear.a_body): R^2 = 0.99959, adjusted R^2 = 0.99884, RMSE = 1.7867e-1 (15 runs, 10 terms)
term coefficient std error t
1 1.239930e1 9.6031e-2 1.291e2
linear.m_body -3.124491e0 5.6500e-2 -5.530e1
linear.c_spring 4.985366e-1 5.6500e-2 8.824e0
bump.h 5.198314e0 5.6500e-2 9.201e1
linear.m_body*bump.h -1.249334e0 6.3169e-2 -1.978e1
linear.m_body^2 7.431336e-1 1.1142e-1 6.670e0
...
Pareto front of max(linear.a_body) (min) and max(linear.body.s) (min): 1 runs
run 2: 5.77769e0 6.04319e-1 linear.m_body = 500.000000, linear.c_spring = 20000.000000, bump.h = 0.030000In coded units, the bump height raises the peak acceleration by 5.2 m/s² over half its
range and the body mass lowers it by 3.1 m/s². A heavier body also softens the effect
of the bump (the m_body*bump.h interaction).
- Designs:
fullfactorial withp=lo:hi:levels;frac, 2^(k−p) fractions with minimum-aberration generators, your own--generatorsor a--resolution;ccd(default), with--alpha face|rotatable|orthogonal;bbd, Box–Behnken; andlhs. - Per quantity: R², adjusted R², RMSE and coefficients with standard errors and t-values. Terms the design cannot estimate are dropped and listed.
- Main effects, two-factor interaction tables and, with
--paretofor two quantities, the non-dominated runs.
The workbench's DOE tab picks the design and the quantities and shows main effects, interactions, coefficients and the Pareto front. Use applies a Pareto point's parameters.
Validated enclosures (prototype)
crates/diokle-core/src/validated.rs encloses a simulation: it returns an interval that must
contain the exact end state for every initial state and parameter in a box, rather than one
trajectory. Each step checks an a priori box that contains the solution over the step, and then
computes the end state by one of two schemes, plain Euler or the mean-value form with rotated
coordinates. A third path, affine arithmetic (enclose_affine), keeps linear dependencies between
the states and gives the narrowest enclosure on the test oscillator: about 0.43 wide, against 2.10
for Euler and 25.6 for the mean-value form.
The rounding is outward at each operation, so the result is guaranteed under the usual floating point model, but the affine path's error term is a per-operation allowance rather than a full analysis, and the library is a prototype. It is not on the command line.
Identifiability
crates/diokle-core/src/identifiability.rs takes the sensitivities of a simulated experiment and the measurement noise, and returns the Fisher information of the parameters, their standard errors (from its inverse, the Cramér-Rao bound) and the pairs that cannot be told apart. A pair whose sensitivity vectors are proportional, such as two parameters that only enter as a product, is reported directly as confounded, so the result does not depend on the inverse. The module is a library function for now; it is not on the command line or in the workbench yet.
Instant surrogates
crates/diokle-core/src/surrogate.rs fits a quadratic response surface to the results of a sweep
or a design of experiments, so a new point can be estimated without a simulation. The inputs are
scaled to [-1, 1] over their sampled ranges. Every holdout_every-th point is held out, and the
root-mean-square error on those points is reported with every prediction.
A prediction outside the sampled box is refused, and a caller can set a limit on the error with
predict_checked: above it, the exact model should be run instead. Quadratic surfaces are
inaccurate across strongly nonlinear designs, and the held-out error is what shows it. The
error is one number for the whole surface, so it does not say where the surface is poor. The
module is a library function for now; it is not on the command line yet.
Fault injection and FMEA
crates/diokle-core/src/faults.rs runs each fault at each operating point and compares the result
with the nominal run of that point. A fault is a set of parameter overrides, such as a pump stuck
off or a leak that opened. The largest deviation of an output is measured against that output's
own nominal range, so outputs in different units can be compared. The effect of a fault is
Failed when the deviation reaches the failure threshold, Degraded when it reaches the degraded
threshold, and None otherwise. A faulted run that does not finish is also Failed.
The result is a failure mode and effects table (FMEA): one row per fault, one column per operating
point, with the deviation in each cell, and to_markdown() writes it as a table. Requirements are
not part of this first version; the output deviation is the only criterion. The module is a
library function for now; it is not on the command line yet.
Checked against known answers
crates/diokle-core/tests/analysis.rs compares these analyses with analytic results:
exponential decay, a mass-spring-damper, the Ishigami function's Sobol indices, Monte
Carlo moments, and parameter recovery from synthetic data.